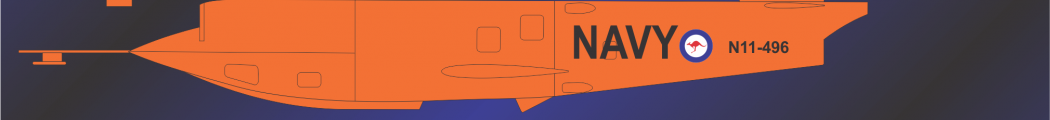

The GAF Jindivik is a remotely controlled target, designed and produced by the Government Aircraft Factory (GAF). The name is from the Aboriginal language, meaning “the hunted one”. Used extensively in Australia, the United Kingdom and in small numbers by Sweden and the United States, the Jindivik served initially as a target, but later was employed as a target tug.
We are developing the model to be used as a slope soarer or small EDF. Currently, we are still working on the design, but hope to have it ready for distribution soon. Email us for information.
GAF Jindivik – Design, Development, Production and Performance
The Government Aircraft Factories (GAF) Jindivik was one of Australia’s greatest aerospace engineering achievements and one of the world’s most successful early unmanned aircraft. Developed from the late 1940s as a pilotless, radio-controlled jet target drone, it was designed to support guided missile development and weapons training. Although originally intended as an expendable target, the Jindivik proved so reliable and recoverable that individual aircraft routinely flew many missions before retirement.
The Jindivik served with the Royal Australian Air Force (RAAF), Royal Australian Navy (RAN), Royal Air Force (RAF), the United States Navy, and the Swedish Air Force. Production extended from 1952 until 1986, with a final batch built in 1997, making it one of Australia’s longest-lived military aircraft programmes. Between 502 and 517 aircraft were produced, depending on whether prototypes and the final production batch are included.
Origins
In 1948, Australia and the United Kingdom agreed to cooperate in the development and testing of guided weapons. Britain would provide missile technology while Australia would provide the extensive test facilities at the Woomera Rocket Range in South Australia.
Britain’s Ministry of Supply issued Specification E.7/48, calling for a pilotless aircraft capable of:
- a 15-minute mission
- operation to 40,000 ft
- high subsonic speed
- repeated recoverable flights
- radio control from the ground
Responsibility for the aircraft fell to the Government Aircraft Factories (GAF) at Fishermans Bend, Melbourne, under chief designer Ian Fleming (not the novelist), working closely with the Aeronautical Research Laboratory and the Long Range Weapons Establishment.
Development
The Pika
Before producing an unmanned aircraft, GAF built two manned proof-of-concept aircraft known as the Pika (“flier”).
The Pika allowed engineers to evaluate:
- aerodynamic characteristics
- engine installation
- control response
- structural behaviour
- radio-control concepts
Unlike the production Jindivik, the Pika featured:
- a cockpit
- retractable landing gear
- side-mounted engine air intakes
The first Pika flew in 1950, successfully validating the design.
Jindivik Mk.1
The first unmanned Jindivik flew on 28 August 1952 at Woomera.
Major changes from the Pika included:
- removal of the cockpit
- dorsal engine intake
- landing skid replacing wheels
- autonomous autopilot
- radio-command guidance
The Mk.1 was powered by an Armstrong Siddeley Adder turbojet, but only 14 aircraft were built before a more powerful engine became available.
Design Philosophy
The aircraft was designed around several requirements:
- extremely high reliability
- repeated recoverable operation
- accurate flight path control
- low operating cost
- high-speed target simulation
- ease of maintenance
Unlike modern UAVs, the Jindivik carried no onboard pilot or autonomous mission computer. Instead, it relied on a sophisticated autopilot that received commands from operators on the ground.
Airframe Design
Wing
The Jindivik employed a cantilever low wing.
Characteristics included:
- all-metal stressed-skin construction
- swept leading edge
- relatively thin aerofoil
- short span for high-speed operation
The wing was optimised for:
- subsonic flight
- stability
- high manoeuvrability
- operation from sea level to very high altitude
Wingtip shoes protected the structure during skid landings.
Fuselage
The fuselage was an all-metal semi-monocoque structure incorporating:
- streamlined nose
- equipment bay
- autopilot
- radio receiver
- fuel tanks
- turbojet engine
The dorsal engine intake reduced the risk of foreign-object ingestion during launch and skid recovery.
Guidance and Control
One of the Jindivik’s greatest innovations was its radio-command guidance system.
Unlike direct manual remote control, operators transmitted commands to an onboard autopilot, which interpreted and executed manoeuvres.
Capabilities included:
- heading changes
- altitude changes
- speed control
- climb and descent
- automatic flight stabilisation
The system accepted 18 primary flight commands plus additional commands for onboard equipment such as smoke generators and countermeasure devices.
Launch System
The Jindivik did not use conventional landing gear.
Instead it was launched from a reusable self-steering trolley.
The launch sequence was:
- Engine accelerated to full thrust.
- Aircraft accelerated along the runway on the trolley.
- At approximately 110 kt, the autopilot selected take-off flap and rotated the aircraft.
- The drone separated from the trolley and climbed away.
This eliminated the weight and complexity of retractable or fixed landing gear.
Recovery System
Recovery was equally innovative.
The aircraft approached under radio control before touching down on a centreline skid.
Directional control after touchdown relied on:
- wingtip skid shoes
- aerodynamic control surfaces
- careful guidance from two ground controllers monitoring azimuth and elevation
This system proved remarkably successful and enabled repeated reuse of each aircraft.
Powerplant Development
Mk.1
- Armstrong Siddeley Adder ASA.1
- Disposable turbojet
- Approximately 1,050 lbf thrust
Mk.2 onwards
- Armstrong Siddeley Viper
- Approximately 1,640 lbf thrust
Later versions
- Bristol Siddeley/Rolls-Royce Viper 201
- 2,500 lbf thrust
The Viper dramatically improved:
- climb performance
- reliability
- altitude capability
- maximum speed
Although originally designed for only around 10 hours of operation, later versions achieved substantially longer service lives.
Variants
Major production variants included:
- Mk.1 – Adder-powered initial production
- Mk.2 – Viper-powered production model
- Mk.2A – Improved intake and wider wings
- Mk.2B – Main production version
- Mk.3A – Higher-altitude capability
- Mk.3B – Standard late-production model
- Mk.102/103 – RAF versions
- Mk.203 – Royal Australian Navy versions
- Mk.303 – United States Navy export version
Each successive version incorporated improvements in engines, avionics and mission equipment.
Operational Equipment
Depending upon mission, the Jindivik could carry:
- smoke generators
- infrared decoys
- radar reflectors
- electronic countermeasure pods
- target-towing equipment
- flare dispensers
- telemetry systems
- camera systems
These enabled it to simulate enemy aircraft and missiles during realistic training exercises.
Production
Manufacturer
- Government Aircraft Factories (GAF)
Location
- Fishermans Bend, Victoria, Australia
Production timeline:
- Design commenced: 1948
- First flight: 1952
- Main production: 1952–1986
- Final production batch: 1997
Production totals are commonly quoted as:
- 502 aircraft built during the original production run
- 517 aircraft including the final batch produced in 1997
Examples supplied to the United Kingdom were shipped as subassemblies and completed by Fairey Aviation before entering RAF service.
Specifications (Jindivik Mk.3B)
| Item | Specification |
|---|---|
| Crew | None (pilotless) |
| Length | 8.15 m (26 ft 9 in) |
| Wingspan | 6.32 m (20 ft 9 in) |
| Height | 2.08 m (6 ft 10 in) |
| Wing Area | 7.06 m² (76 sq ft) |
| Empty Weight | 1,315 kg (2,900 lb) |
| Maximum Take-off Weight | 1,655 kg (3,650 lb) |
| Engine | Rolls-Royce/Bristol Siddeley Viper 201 turbojet |
| Thrust | 2,500 lbf (11.1 kN) |
Performance
| Performance | Value |
|---|---|
| Maximum Speed | 490 kt (908 km/h; Mach 0.85–0.86) |
| Service Ceiling | 57,000 ft (17,375 m) |
| Range | 540–670 NM (1,000–1,240 km), depending on variant |
| Launch Speed | Approximately 110 kt |
| Landing Speed | 125–150 kt |
Operational Service
The Jindivik entered RAAF service in 1953 and was soon adopted by the RAF for missile development and weapons training. It became a mainstay at the Woomera Test Range and later at the Jervis Bay Range Facility, where it was used extensively by the RAN for testing systems such as the Seacat, Tartar, and Sidewinder missiles.
Because of its high reliability, it evolved from being merely a target into a sophisticated threat simulator capable of towing targets, deploying decoys, trailing smoke, and emulating anti-ship missiles. Its versatility and durability allowed it to remain in service until 1998, when it was replaced by the BAE Kalkara target drone.
Legacy
The GAF Jindivik was one of Australia’s most successful aerospace exports and an early pioneer of unmanned aviation. Its robust airframe, advanced radio-command guidance system, recoverable launch-and-skid landing arrangement, and impressive jet performance made it decades ahead of its time. Over a service life spanning almost half a century, it played a critical role in the development of missile systems for Australia, the United Kingdom, the United States, and Sweden. Today, the Jindivik is recognised as a landmark achievement in Australian aerospace engineering and an important precursor to modern unmanned aerial vehicles (UAVs).